← All problemsEngineering Lab

Engineering task brief

Mass-Spring-Damper Engineering Lab

Control the position of a mass connected to a spring and damper. The design must remain accurate when the mass changes and recover from an external force pulse.
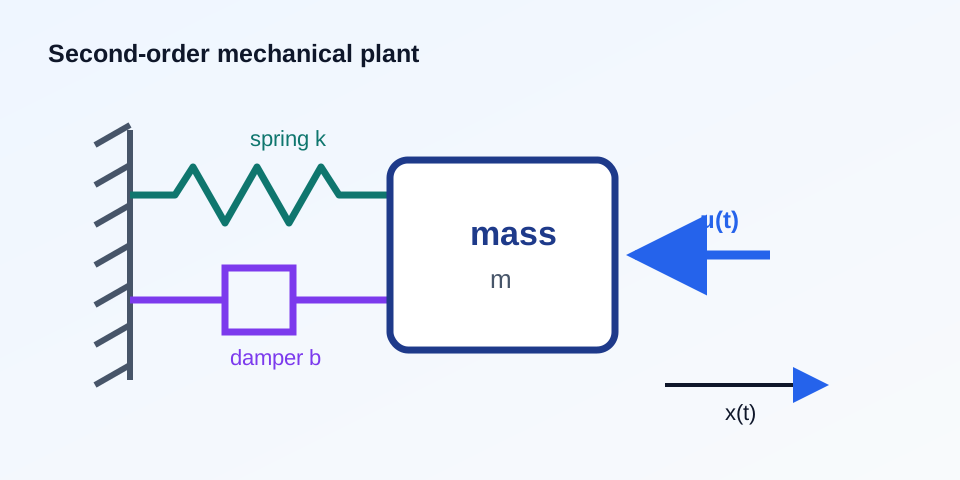
Model
G(s) = 1 / (s² + 10s + 20)
Mass
1 normalized unit
Damping
10
Spring stiffness
20
Input
Force (N)
Output
Position (m)
Mass, spring, and damper connected to an applied control force

Nominal Tracking

Track a 1 m command with the nominal mass.

Mass +20%

Repeat the command with 20% more mass.

External Force Pulse

Reject a 0.2 N force pulse applied from 3 s to 4 s.

Actuator constraint: Applied force must remain between -2500 and 2500 N. Your final delivery includes a controller choice, experiment evidence, multi-scenario validation, and a short design conclusion.

Learning objectives

  • ✓ Understand second-order dynamics
  • ✓ Compare P, PI, PD and PID action
  • ✓ Balance settling, overshoot, error and force
  • ✓ Test robustness to mass variation