
Nominal Positioning
Move the ball to 0.25 m. The 8 s target reflects the physical minimum imposed by the ±0.15 rad beam limit.
Engineering task brief
Control a double-integrator ball position using a limited beam angle. Reverse the target and study derivative filtering under measurement noise.
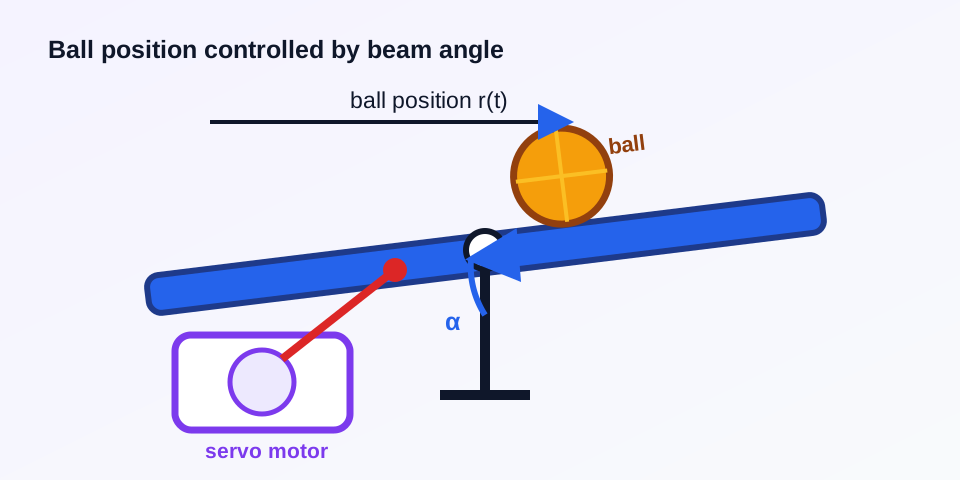
Move the ball to 0.25 m. The 8 s target reflects the physical minimum imposed by the ±0.15 rad beam limit.
Move to 0.25 m, then reverse to -0.25 m at 4 s. The calibrated reversal target is 11 s after switching.
Track 0.25 m with deterministic 0.002 m measurement noise.